Integrated Controller
- Traction + pump + steering control in a single unit (KD210)
- 24V–60VDC wide voltage range
- Built-in PLC function with open programming environment
Application solution · AMR / FORKLIFT
Quick answer
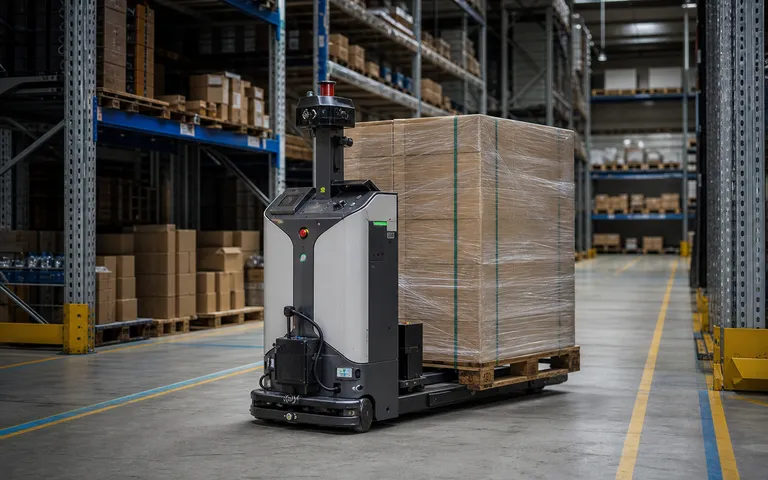
An autonomous forklift needs coordinated traction, steering, pump control and an operator interface. This architecture reviews Kinco KD200 or KD210 vehicle control, SMC130D motion hardware, iSMD or iGMK steering modules, and the G2100H-CTP HMI against the platform’s voltage, duty and communication needs.
Autonomous forklift OEMs building narrow-aisle pallet movers, stackers, reach trucks or straddle stackers and evaluating integrated traction, steering, pump control and model-specific certification evidence.
Reference architecture · Model-specific review
Control problem
Four scoping blocks show the review path; they are not a wiring diagram.
Review the battery loop, fusing and emergency disconnect against the vehicle platform.
Choose KD210 when traction and pump control are combined, or KD200 for traction-only duty, subject to application review.
Size the SMC130D drive and motor plus the iSMD or iGMK steering option from lift duty, power-cycle behavior and startup-position needs.
Review CAN termination and the G2100H-CTP screw-lock HDMI and VGA connections for the selected operator interface.
Use this table to compare component roles, exact model names and key specifications before application review.
| Role | Component | Key spec |
|---|---|---|
| CTRL | Kinco KD210-1-250-L | Integrated traction + pump (24V/48V) · controls 3-phase async/sync |
| CTRL | Kinco KD200-1-250-L | Traction-only controller (24V/48V) |
| DRIVE | Kinco FD164S-AB-000 | 1.5–3 kW servo drive · for SMC130D pairing |
| DRIVE | Kinco FD125-AB-000 | Steering drive · 24V/48V |
| MOTOR | Kinco SMC130D-0150-30WBK-4DSH-NT03 | 1.5 kW · with GK10 gearbox · for ≤2m lift pallet truck |
| MOTOR | Kinco SMC130D-0300-30WBK-4DSH-NM04 | 3 kW · with GK16 gearbox |
| WHEEL | Kinco iSMD60D-040-DQAK-AA-000 | Integrated steering drive wheel · multi-turn encoder |
| WHEEL | Kinco iGMK60D-040-DMAK-AA-000-G035 | Alternative integrated steering wheel · single-turn encoder |
| HMI | Kinco G2100H-CTP | 10.1" industrial touchscreen · screw-retained HDMI + VGA connections |
Configuration summary. A candidate autonomous-forklift stack combines KD200/KD210 controllers for traction and pump duties, SMC servo motors with model-specific feedback and the G2100H-CTP HMI.
This is a candidate architecture, not a quotation. a line-by-line BOM review checks each line against your machine, and logic re-implementation scopes the control work once the hardware is agreed.
Engineering review needs the vehicle type, battery voltage, payload, travel speed, lift height, steering geometry, duty cycle, communication protocol, safety scope, existing controller or part numbers, and target date. Candidate component sizing and availability are confirmed at RFQ.
A migration review compares the existing controller part number, wiring, I/O, motor feedback, communication protocol, hydraulic-pump duty, steering behavior, safety circuit, enclosure and software responsibilities. Any candidate replacement remains subject to engineering review.
iSMD60D is listed with multi-turn feedback and iGMK60D with single-turn feedback in the referenced configuration. Encoder behavior, mechanical envelope, mounting and shaft interface must be checked against the exact model drawings and confirmed at RFQ.
Application review
Send the payload, duty, voltage, protocol, safety scope and any existing part numbers you already know.
Limits. These figures describe the stated configuration, not Automation Liberty customer results. This is a candidate architecture; exact model, compatibility, certification, availability and commercial scope are subject to engineering review and confirmed at RFQ.
Independent engineering and sourcing partner. Product names and trademarks are the property of their respective owners and are used for identification only.
Why no list price? Every quote follows an engineering review of your application — you get a validated price, not a catalog number.